Skip to projects

Portfolio

01 / Adaptive VROctober 17, 2026 · Prototype

Dreadloop

Molten Hacks · LA Tech Week · Built in ~12 hours

1:41 · Edited demo with sound and captions.Open video ↗
Project details

Project

A Quest WebXR horror prototype that sends experimental electrical-reaction threshold events to an encounter director. Built at Molten Hacks during LA Tech Week on October 17, 2026.

My contribution

I worked on sensor acquisition, signal processing, and Signal Scope. Nikhil, a first-year UCLA Computer Science and Engineering student, built the VR environment and encounter director.

Signal Scope

The interface includes live channel graphs, recording controls, frame diagnostics, CSV and JSON exports, and manual blink, jaw-clench, and startle markers.

Game integration

Threshold crossings are sent through HTTP event hooks. The sender checks timestamps and duplicate IDs and applies a cooldown. Events carry no emotion label, and detector quality is marked unverified.

measurement: "threshold_crossing"
event: "reaction"
emotion: null
detector.quality: "unverified"

Limitations

Chip identification, register readback, and frame validation remained unresolved. The signals were not validated measurements of fear or muscle activity. The video is an edited demonstration, not a synchronized record of reactions causing encounters.
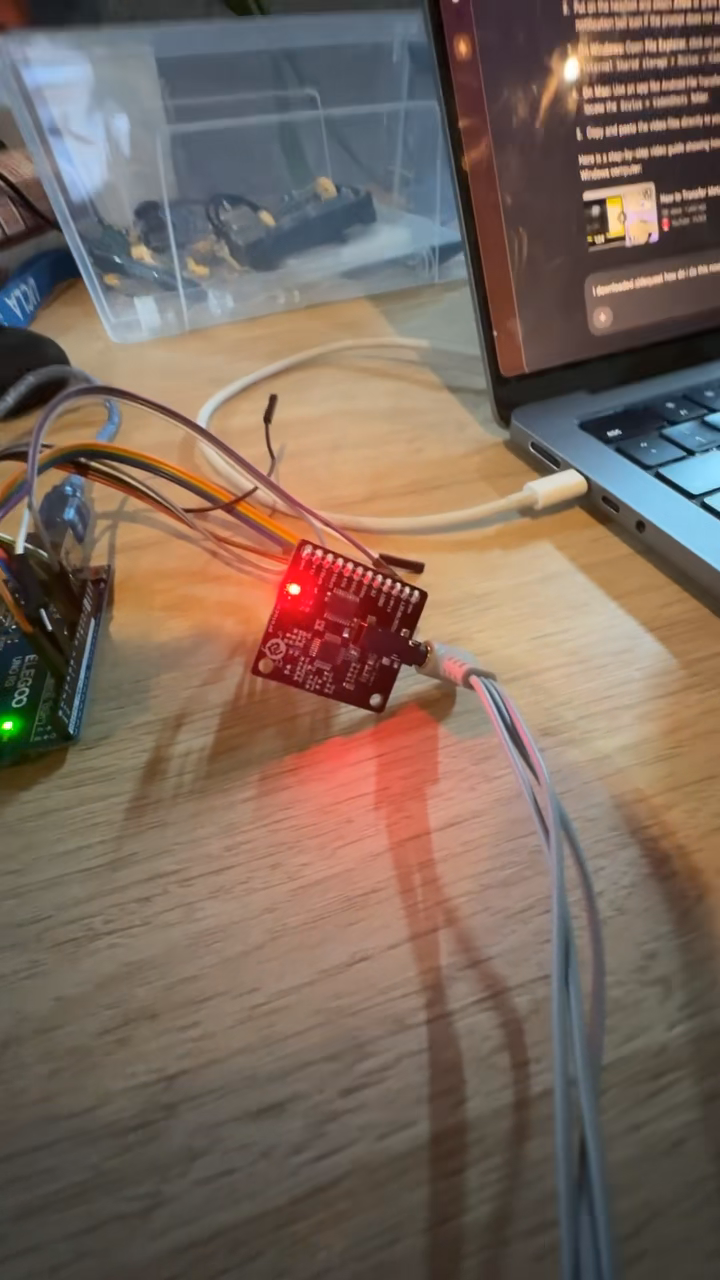
Wired sensor board and prototype electronics on a workbench beside a laptop
Sensor hardware.
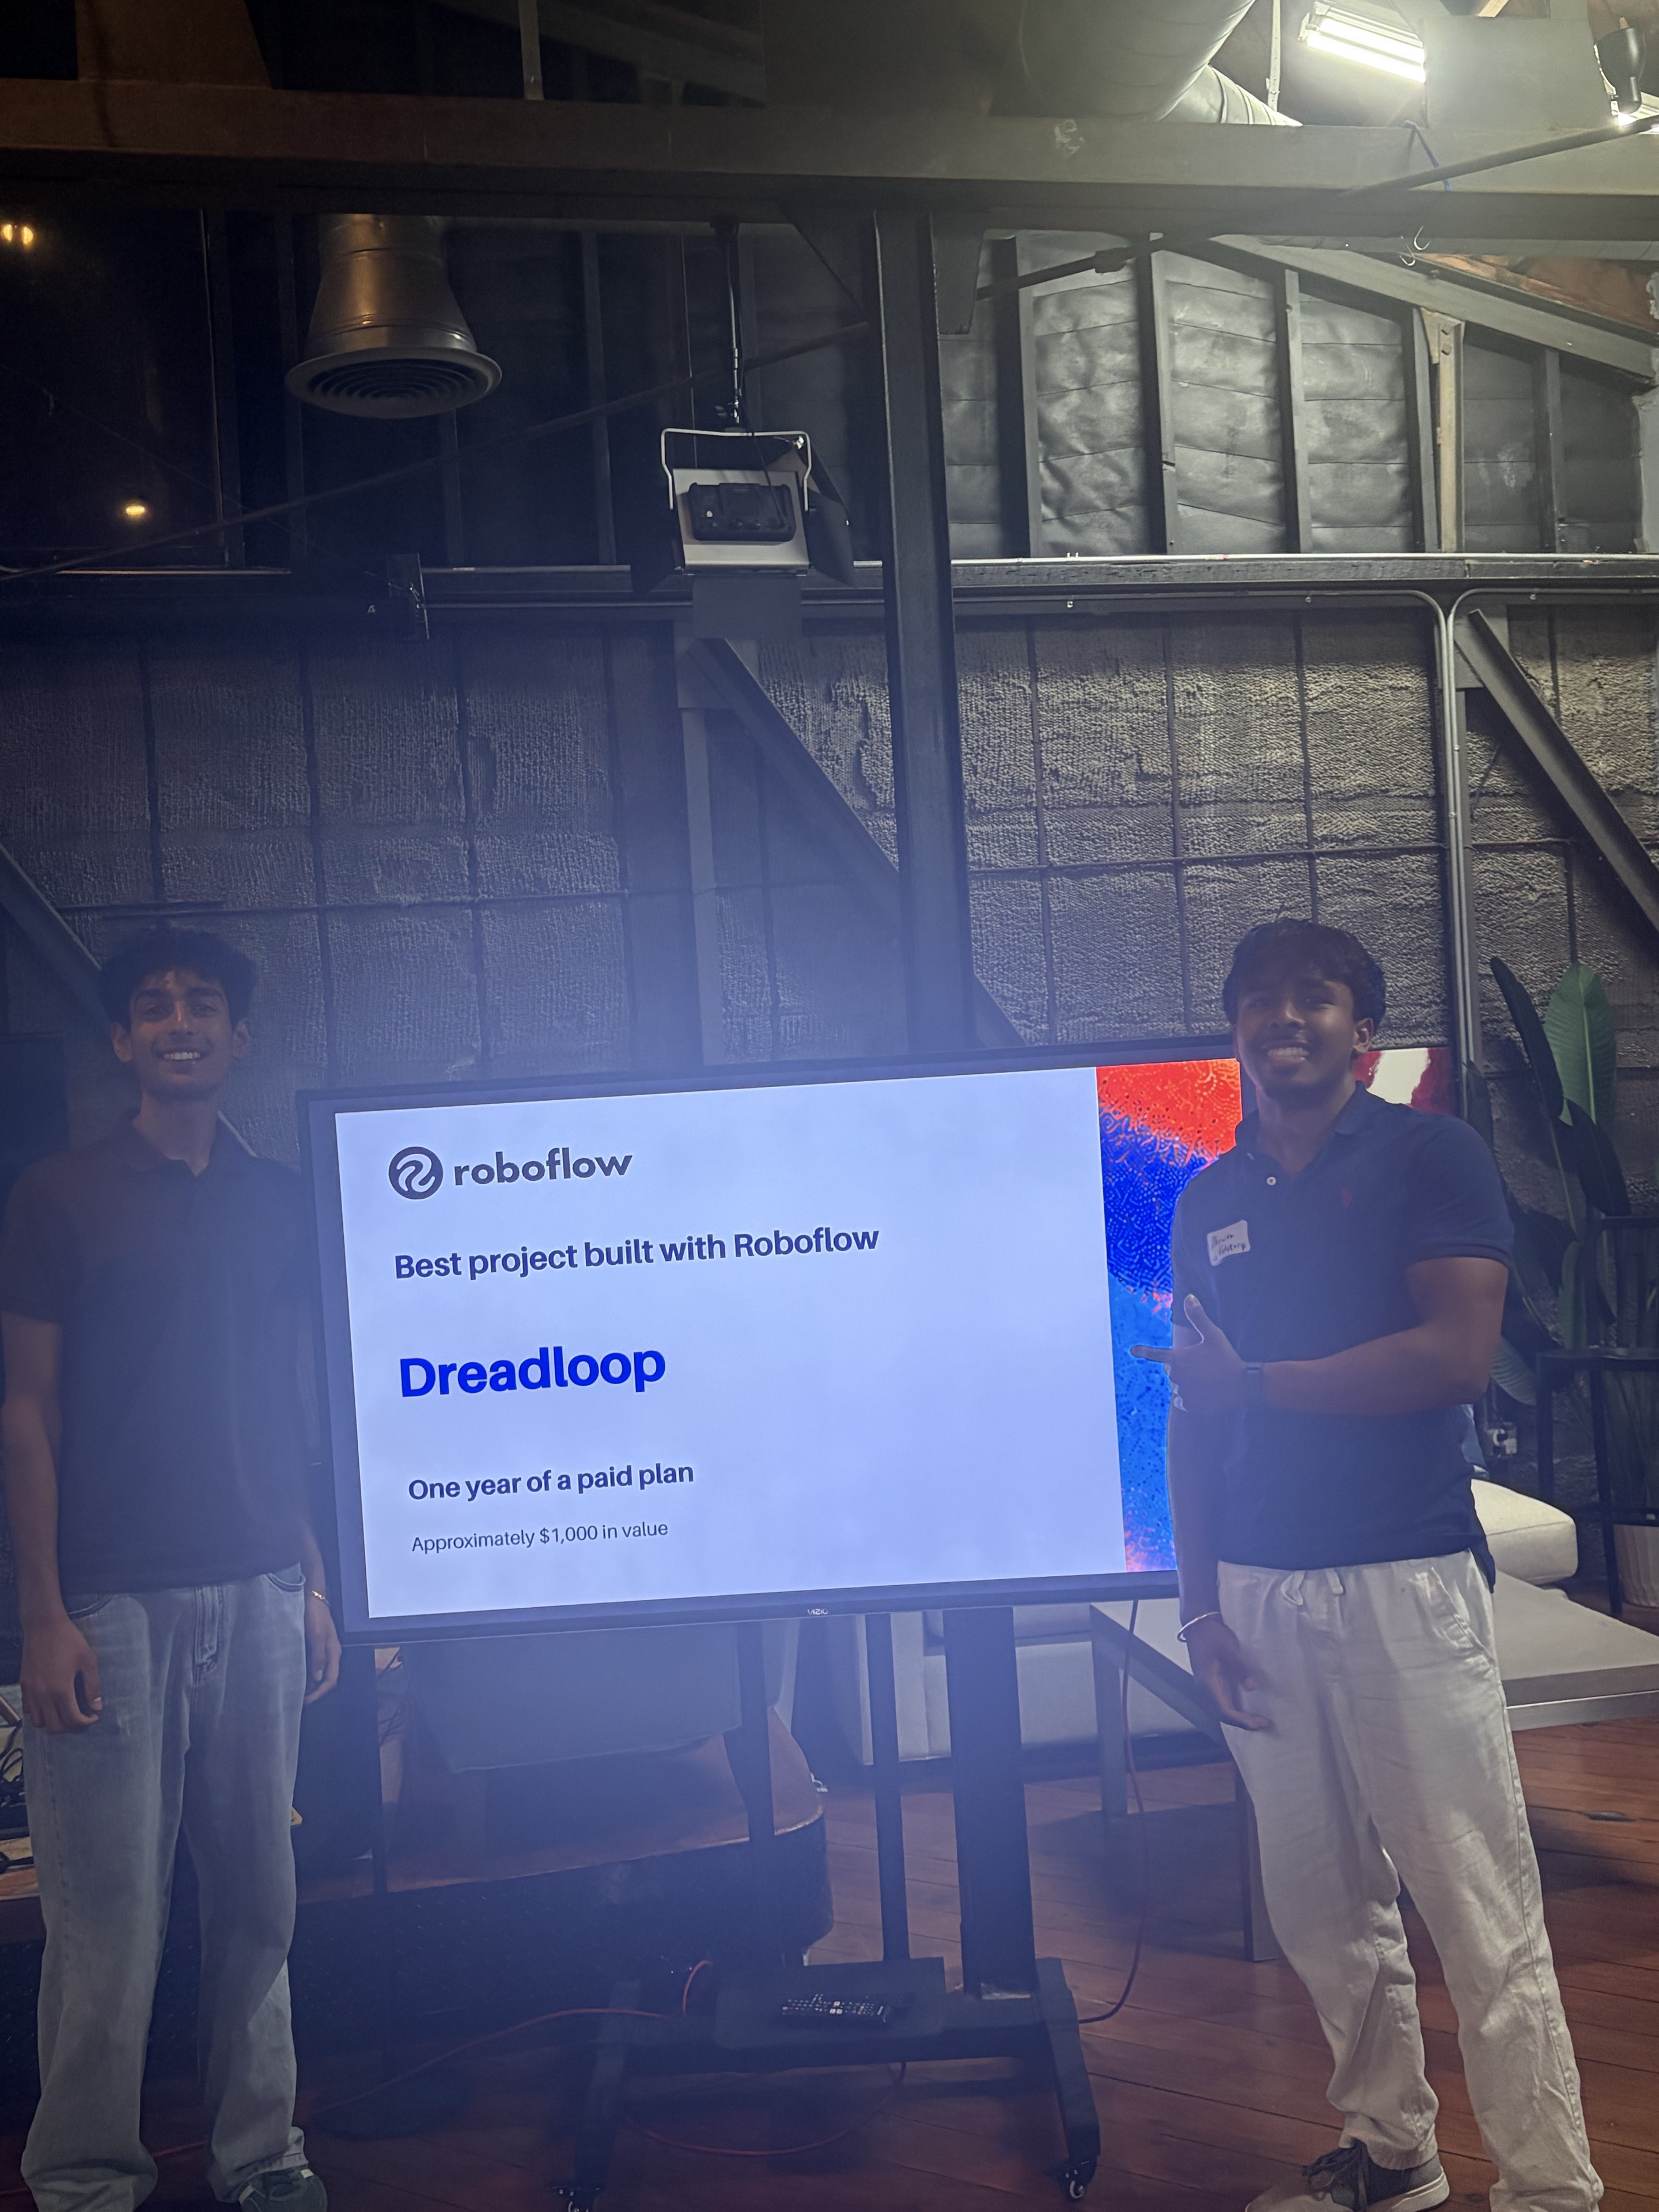
Dreadloop team beside a Roboflow award display reading Best project built with Roboflow
“Best project built with Roboflow.” Sponsor prize: one year of a paid plan, valued at approximately $1,000.
  • WebXR / Quest
  • Three.js
  • Signal Scope
  • HTTP events
View game repository ↗
02 / Competition robotics

VEX Robotics

Team 3134R Ranger · 2021–2026

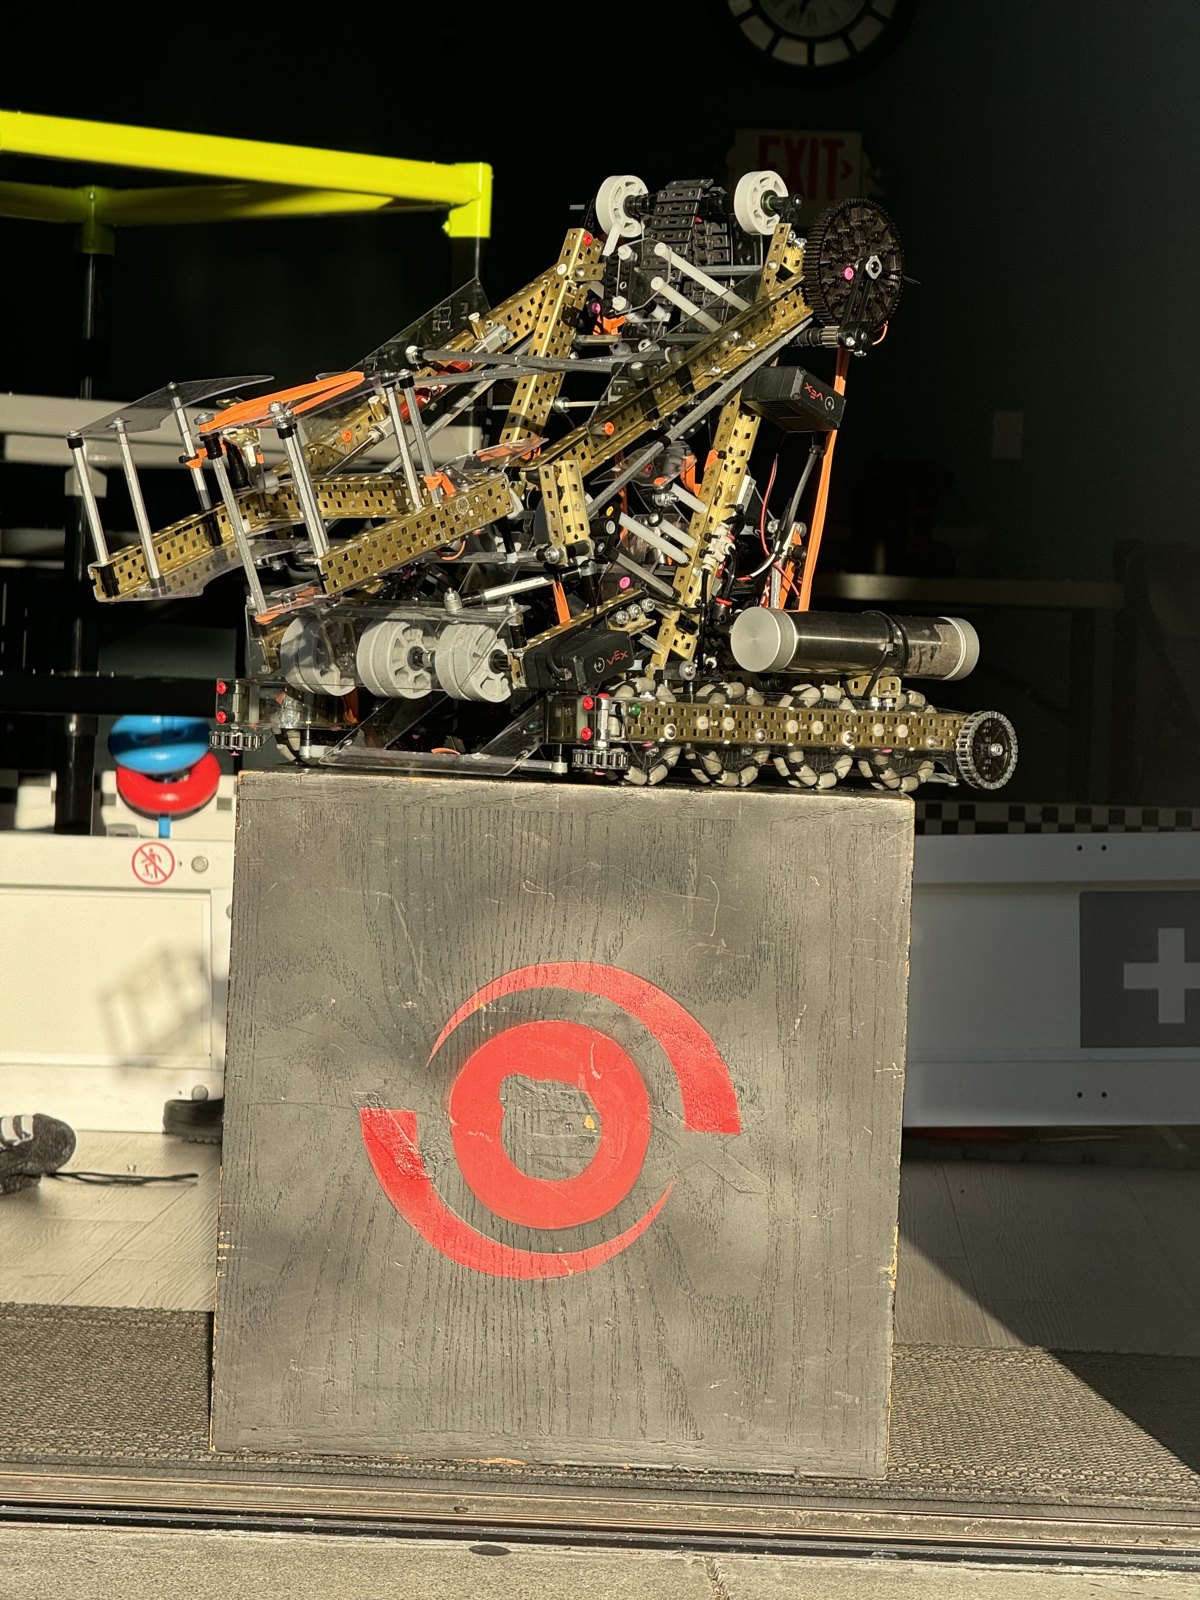
Four seasons of building competition robots, from the drivetrain and mechanisms to autonomous motion control.

Competition robot with a metal frame, angled mechanism, and exposed wiring
Robot mechanism and wiring.
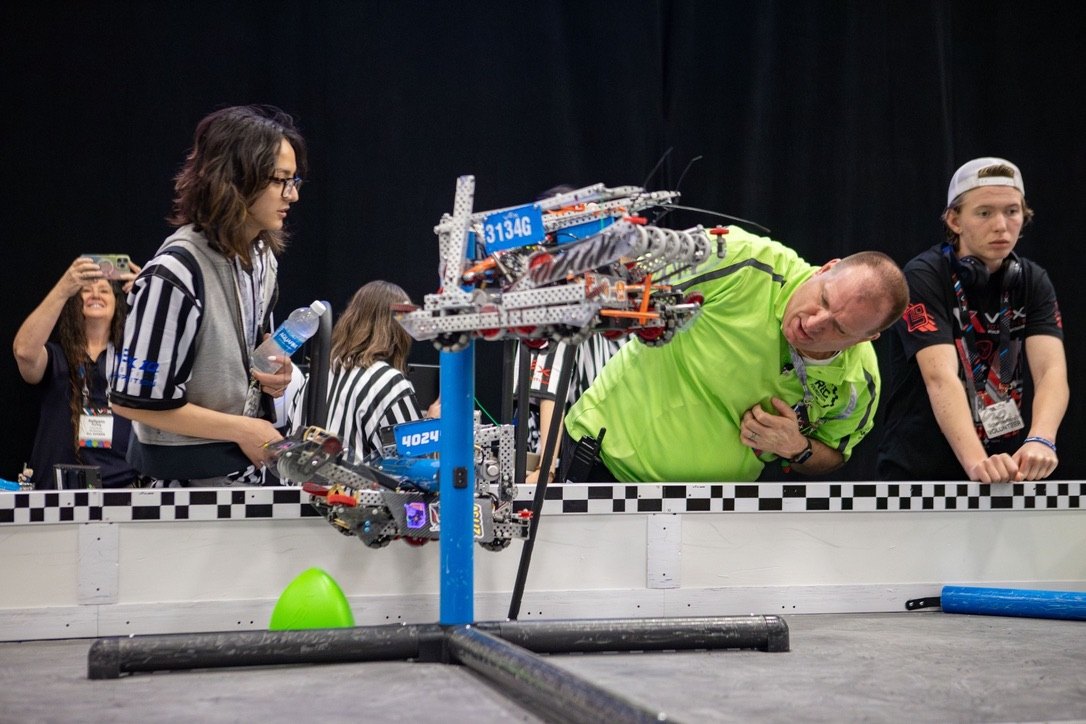
Officials inspecting a VEX robot beside the competition field
Competition inspection.
Project details

My contribution

I captained an 11-person team that built 11 robots across four seasons. I designed drivetrains, odometry pods, and pneumatic systems in Fusion 360, then manufactured parts with a Tormach 1100M CNC mill and a laser cutter.

On the software side, I programmed autonomous routines in C++ using PID control, trapezoidal motion profiles, pure pursuit path planning, IMU integration, and odometry.

  • C++
  • PID & path planning
  • Fusion 360
  • CNC & laser cutting
03 / Wearable hardware

MallowMask

UPenn M&TSI · Summer 2025

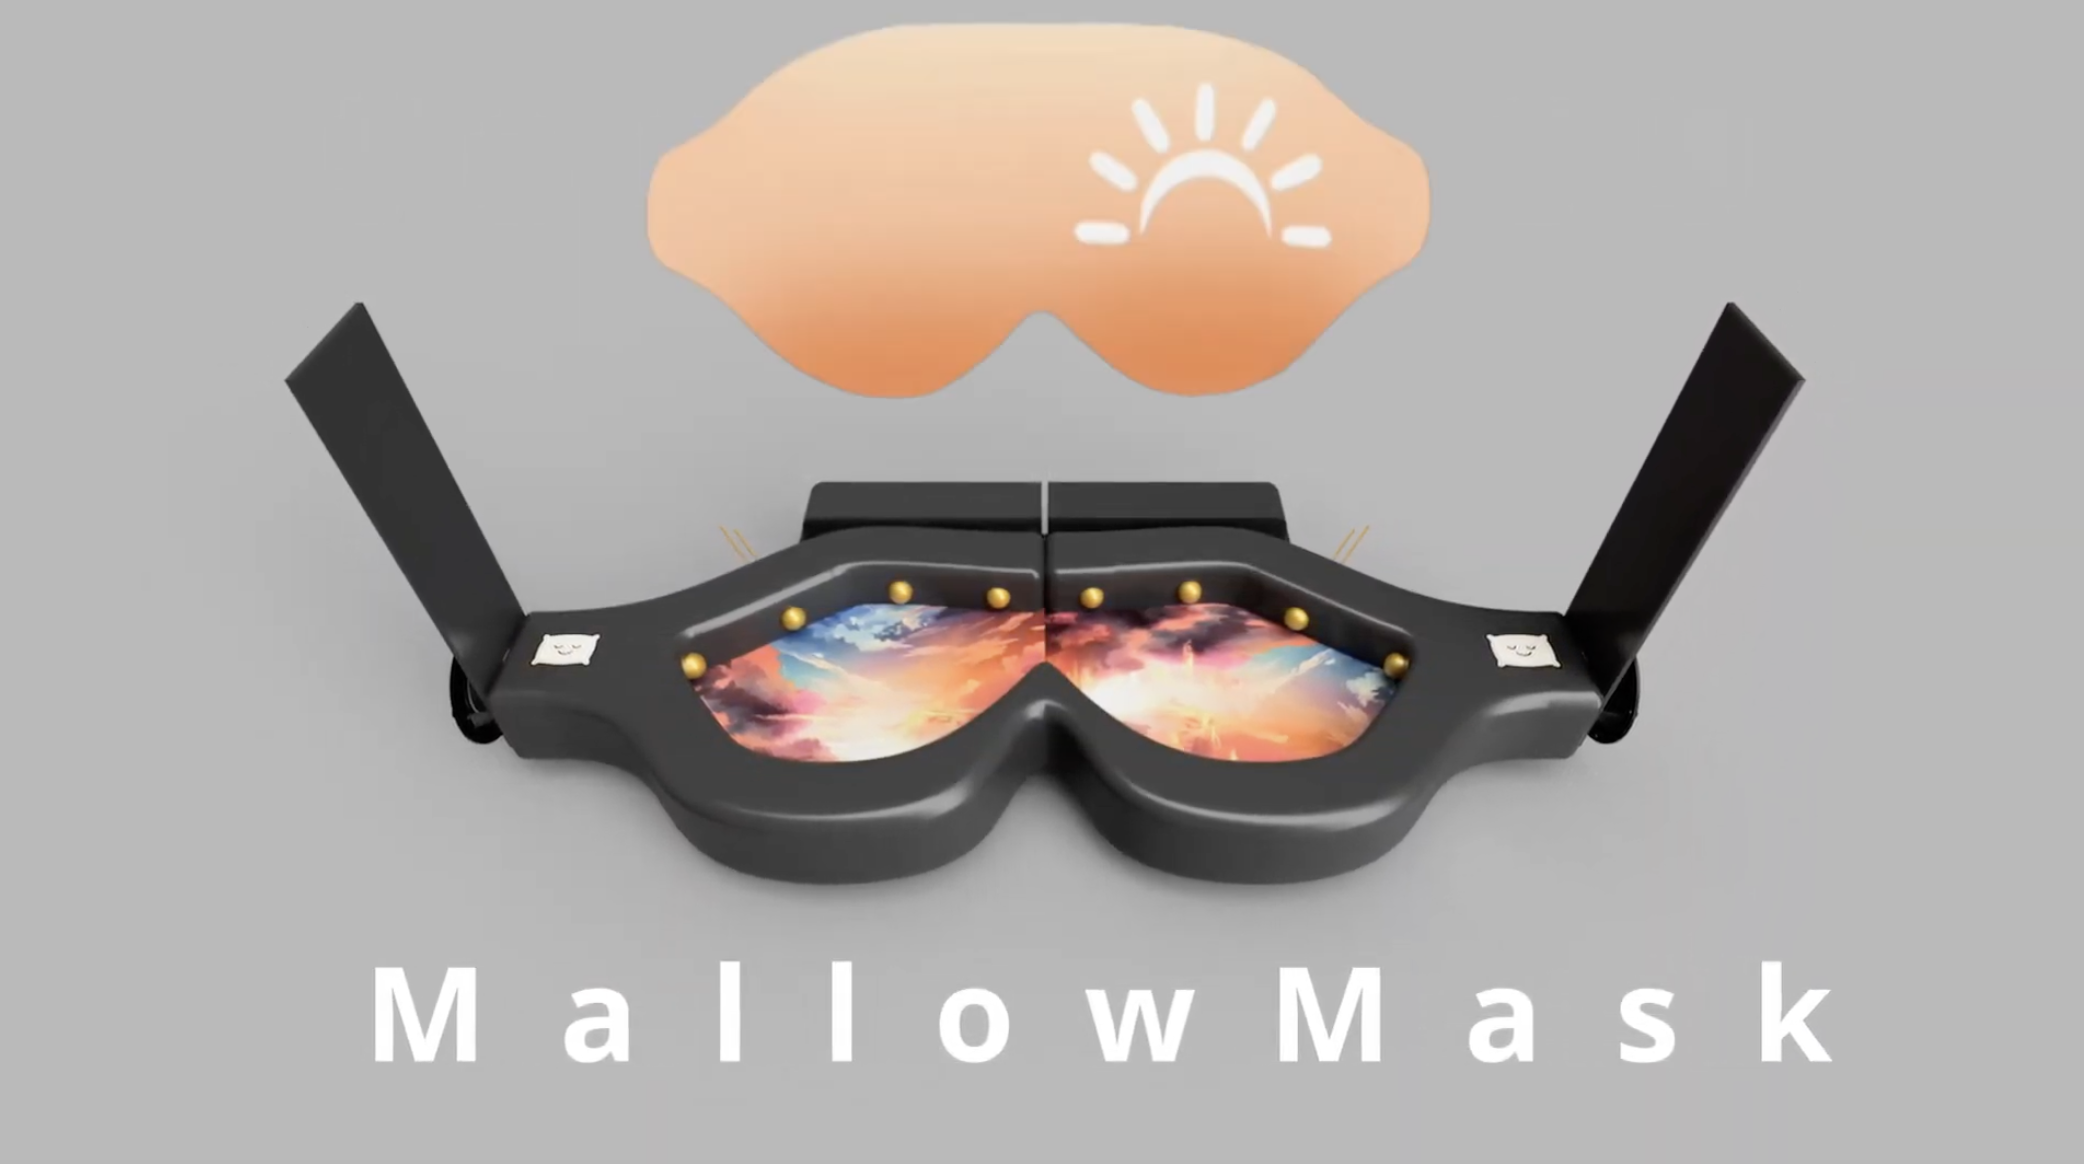
A connected sleep-mask prototype with light, vibration, and heating controls, built around an Arduino Uno R4 WiFi.

MallowMask product render showing the mask housing, eye inserts, and LED positions
Product render.
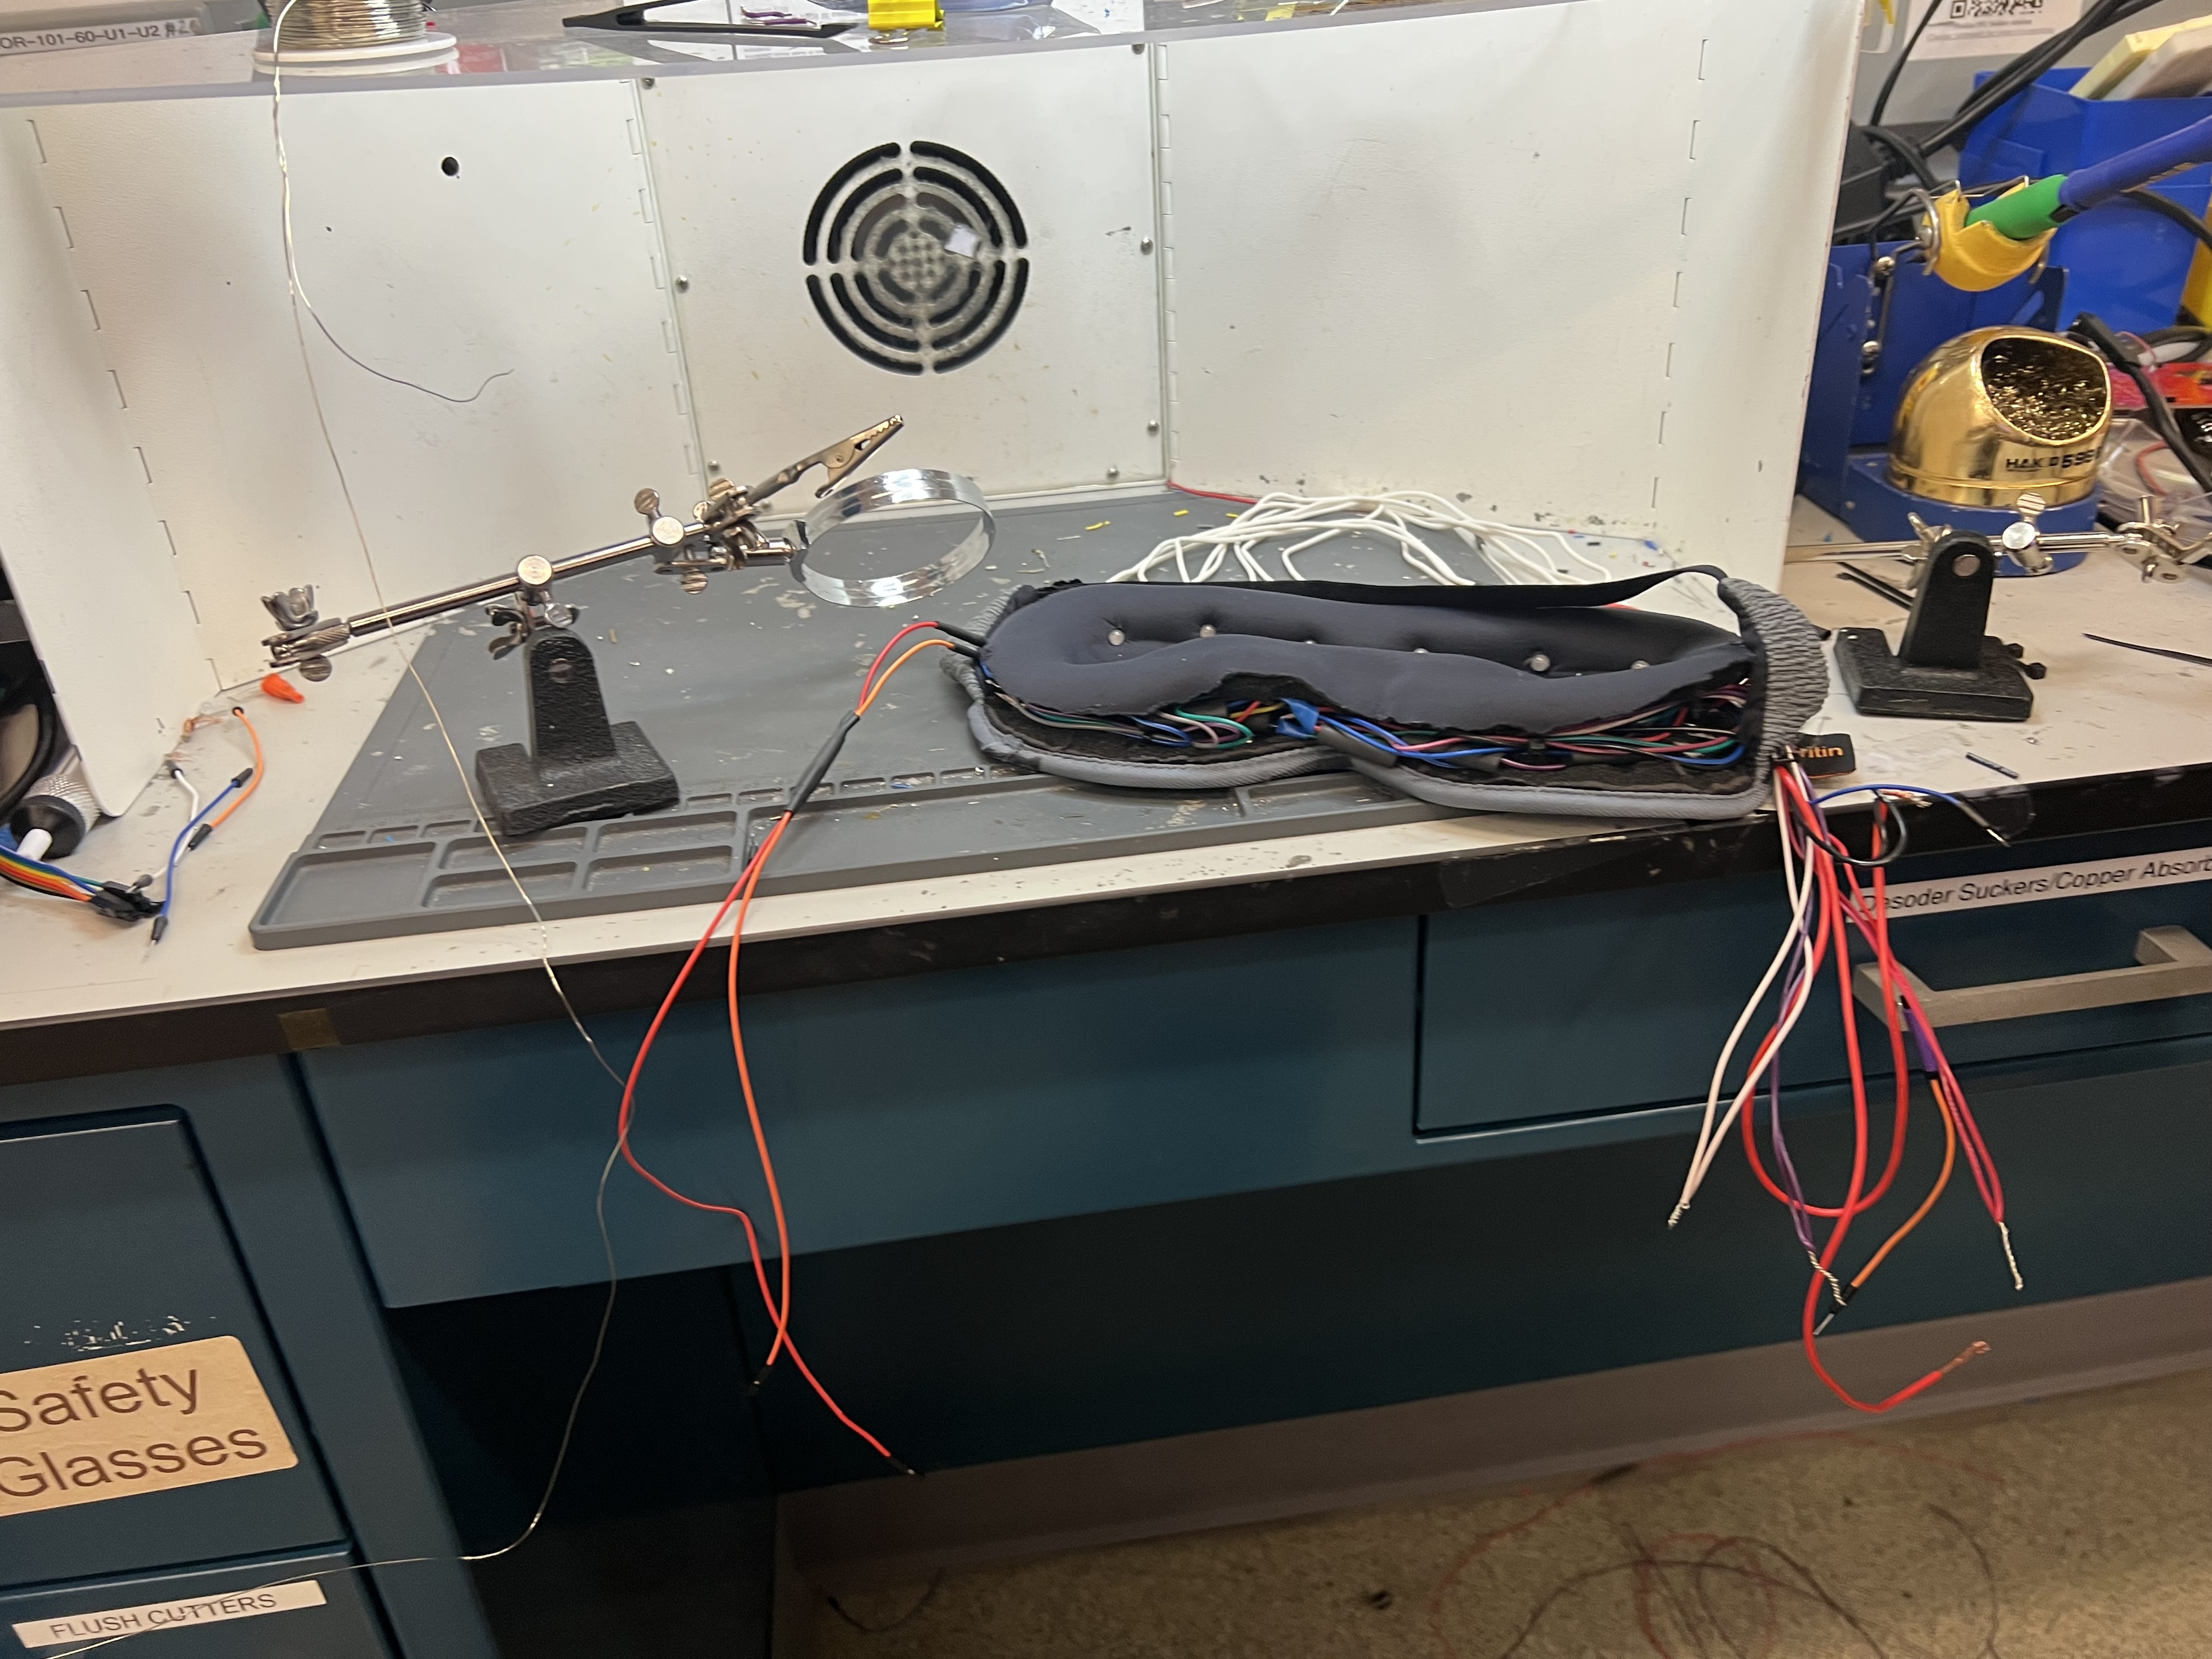
Physical MallowMask prototype with exposed wiring and LEDs at an electronics workbench
Physical prototype.
Project details

My contribution

I worked on the hardware design and integration: Arduino-controlled LEDs, haptic motors, heating elements, and a Blynk IoT connection to the app.

The project repository includes a React and TypeScript interface, alarm and routine controls, and firmware that maps app commands to LED brightness, vibration, and heating outputs.

MallowMask won the Best Product Award at UPenn’s Management & Technology Summer Institute, presented by Professor Gad Allon. Sleep sensing and personalized wake-up models remain future work.

  • Arduino Uno R4 WiFi
  • Blynk IoT
  • React / TypeScript
  • PWM control
View App & firmware ↗

Software

Snoopy AI

Project details

An AI phone agent for dry-cleaning businesses. Customers can place or check orders by voice; an owner dashboard reads and updates the same Notion records.